Jianming Wang王建明
I am an investor drawn to frontier technology. I like to go deep into the fields I follow: tracing an idea back to its origins, understanding how a system works, and listening to the people trying to build what comes next.
My investments span enterprise services, AI, hardware, and robotics. In recent years, my main focus has been AI-powered robotics and physical AI—how intelligence learns to perceive, understand, and act in the physical world.
I hold a master’s degree in Finance from the Wang Yanan Institute for Studies in Economics at Xiamen University, and a bachelor’s degree in Aircraft Propulsion Engineering from Xiamen University. I previously worked as an auditor at KPMG and am a CFA charterholder.
Writing and conversation are part of how I do research. I run Smart Note, a blog on embodied AI, where I interview researchers and founders and explore human data, world models, and the history of robotics. Through the ReSpark podcast, I continue these conversations in a format that leaves room for questions, uncertainty, and the thinking behind each idea.
Smart Note
Embodied AI BlogInterviews, deep dives, and notes on how intelligence meets the physical world.
Articles
A Century of Robotics, EP01: From Science Fiction to Reality, 1920s–1960s
From Čapek’s theater and Asimov’s Three Laws to Unimate and the Stanford Arm: how industry and AI laboratories converged to shape modern robotics.
World Models EP06: VPP
A conversation with Yucheng Hu and Yanjiang Guo on VPP, BagelVLA, and Ctrl-World: video generation, unified models, and robot decision-making.
ModalityNet: Compiling Human Data into Learnable Robot Data
A full conversation with Noitom Robotics founder Ruoli Dai about MOV, OM, ITW, cross-embodiment transfer, multimodal sensing, and the World Compiler.
A Conversation with Jianyuan Wang: 3D Reconstruction Foundation Models—VGGT and VGGT-Ω
Jianyuan Wang on the evolution of 3D reconstruction, geometry-aware foundation models, data quality, and the path from digital to physical intelligence.
World Models EP05: Wenlong Huang on PointWorld and 3D World Models
A full conversation with Wenlong Huang about unified 3D state and action representations, PointWorld’s data pipeline, and counterfactual reasoning for robotics.
A Conversation with Bowen Wen: How FoundationStereo Is Transforming Stereo Vision
Bowen Wen discusses FoundationStereo, Fast FoundationStereo, depth estimation and the role of 3D perception in robot manipulation.
World Models EP04: Motus
Hengkai Tan explains Motus’s unified modeling of video and action, its latent actions, three-stage training and six-level data pyramid, and different routes from world models to robot policies.
World Models EP03: Robotic World Model
Chenhao Li on autoregressive dynamics models, uncertainty-aware policy optimization, and the goal of continuous online learning for real robots.
World Models EP02: Interactive World Simulator
Yixuan Wang on interactive visual world models, diverse play data, long-horizon stability, policy training, and reproducible evaluation.
A Conversation with Zhengyi Luo: SONIC’s Whole-Body Control Framework
Zhengyi Luo discusses SONIC’s model, motion data, retargeting, applications and the challenges of general-purpose humanoid whole-body control.
A Conversation with Danfei Xu: Human Data Is Robot Data in Disguise
Danfei Xu discusses collecting and modeling human data, human-to-robot transfer and sensorimotor intelligence.
World Models EP01: Shenyuan Gao on DreamZero, DreamDojo and a New Paradigm for Robot Intelligence
A conversation with Shenyuan Gao about DreamZero, DreamDojo, world action models and the technical approaches to robotics world models.
An Interview with Ruoli Dai: Noitom Robotics and the Human-Data Challenge, Part Two
Ruoli Dai explains motion-capture technology, optical and inertial tracking, human-centered data collection and a reusable, cross-embodiment data business.
An Interview with Lei Han: Noitom Robotics and the Human-Data Challenge, Part One
Lei Han discusses reinforcement learning, the human-data pyramid, optical–inertial motion capture, multimodal collection and opportunities for robot manipulation.
Human Data EP08: OmniRetarget
An interview with Lujie Yang on interaction-preserving motion retargeting, hard kinematic constraints, data augmentation, and combining optimization with learning for humanoids.
Human Data — The “Key” to Robot Data: Series Summary
A review of eight Human Data interviews, the human-data pyramid, motion capture versus video, and retargeting methods.
Human Data EP07 — Motion Capture: TWIST2
An interview on TWIST2, low-fidelity motion capture, wearable VR devices, and large-scale humanoid data collection.
Human Data EP06—Motion Capture and Video: GAE
Yuefan Wang discusses General Action Expert, scaling human motion data, supporting different control inputs and building a path from teleoperation to autonomy.
Human Data EP05—Video: HuB
Tong Zhang and Boyuan Zheng discuss extreme humanoid balance, reference motion refinement, balance-aware learning and robust sim-to-real transfer.
Human Data, Episode 4—Video: Junyi Zhang on VideoMimic
Reconstructing human motion and scene geometry from casual videos, training contextual humanoid control, and balancing scalable video data with precise motion capture.
Human Data EP03—Motion Capture: ExBody2
Mazeyu Ji discusses whole-body tracking, motion retargeting, balanced training data, specialist policies and the path from imitation to autonomous tasks.
Human Data EP02 — Motion Capture: GMT
An interview on GMT, general motion tracking, motion-capture datasets, mixture of experts, and whole-body humanoid control.
Human Data, Episode 1: Yanjie Ze on TWIST and Whole-Body Humanoid Teleoperation
Yanjie Ze discusses human motion capture, real-time retargeting, RL plus behavior cloning, GMR and the practical design of whole-body humanoid teleoperation.
Interview with Yilun Du: Embodied Intelligence Through EBMs and Video Generation
Yilun Du discusses composable energy landscapes, video planning, generalization and the research challenges facing general-purpose robots.
Interview with Zhengyi Luo: Inside PHC, a General-Purpose Humanoid Controller
Zhengyi Luo traces his path from character animation and UHC to PHC, explains progressive multiplicative control and AMASS motion tracking, and discusses skill reuse and the challenges of real-world humanoid control.
A Conversation with Zhongyu Li: Building the “Cerebellum” of Legged Robots
Zhongyu Li discusses six years of research on model-based control, reinforcement learning, agility, whole-body loco-manipulation, multi-robot cooperation, safety, and transparent hardware.
Xue Bin (Jason) Peng: Toward a General-Purpose Controller for Humanoid Whole-Body Motion
A complete interview on DeepMimic, AMP, ASE, MaskedMimic, sim-to-real transfer, generative control and humanoid hardware.
OSH EP01: ToddlerBot—An Open-Source Small Humanoid from Stanford
An interview with ToddlerBot's creators on reproducible humanoid hardware, locomotion, manipulation and community development, alongside our own build.
RFM, Episode 5: Lucy Xiaoyang Shi on Hi Robot—Teaching Robots to Listen and Think
Lucy Xiaoyang Shi explains hierarchical instruction following, high- and low-level policies, grounding, synthetic language data and the data challenges behind π0.
RFM, Episode 4: Comparing the VLA Architectures of π0, Helix and GO-1
An interview-informed guide to VLA architectures, imitation learning, action chunks, asynchronous control and latent action planning, with Chiming Liu of AgiBot.
VoxPoser and ReKep: Task Representations for Zero-Shot Robot Generalization
A full interview with Wenlong Huang on spatial and temporal task representations, relational keypoints, world models, planning and zero-shot manipulation.
Peter Chen: The Next Decade Will Produce World-Class AI and Robotics Companies
A full conversation with Alphaist Partners founder Peter Chen, Zhe Chen, on robotics investing, founders, data, deployment, company building and the new fund.
Cewu Lu: Building Noematrix for Steady Progress and Long-Term Reach
A complete ReSpark conversation on academic research, Flexiv, scalable robot data, force control, embodied models and commercial deployment.
How Reinforcement Learning Improves Large Language Models
Kimi reinforcement learning researcher Whisper discusses post-training, verifiable rewards, inference-time scaling and the methods behind Kimi k1.5.
Conversation with Yunzhu Li: Learning Dynamics for General-Purpose Manipulation
A full conversation on learned physical models, particle representations, graph networks, MPC, deformable objects and the value of modular robot systems.
Reinforcement Learning for Robotics: An In-depth Introduction
Conversations with Weinan Zhang and Yunlong Song on RL algorithms, manipulation, locomotion, drone control, and sim-to-real transfer.
GenDP: Improving Diffusion Policy Generalization with Dynamic 3D Semantics
A conversation with Yixuan Wang about category-level generalization in Diffusion Policy, dynamic 3D representations and learned dynamics with model predictive control.
Genesis Released: Could a New Physics Engine Transform Robot Simulation?
The Genesis launch, differentiable physics, realistic rendering, generative data and the relationship between simulation and real-world learning.
ReSpark Talk: Lai Jie on Astribot and a Journey to the Stars
Astribot founder Lai Jie and investor Ted discuss designing robots for AI, world models, touch, entrepreneurship and the possibilities of a new human–robot relationship.
RFM, Episode 3: Tsinghua’s RDT and the Architectures of Robot Foundation Models
An interview with Songming Liu on RDT-1B, bimanual manipulation, unified action spaces and architectural comparisons with Octo, HPT, ACT, Diffusion Policy and π0.
Podcast: RL + Control—Bringing Robot Reliability Closer to 99.9x%
Jianlan Luo, Guanya Shi, Zongqing Lu, and Qiuguo Zhu discuss reinforcement learning, control, real-world manipulation, and the gap between benchmark success and product reliability.
RFM, Episode 2: From Octo to π0—How to Train a Generalist Robot Policy
Kevin Black’s CoRL 2024 account of Octo’s successes and failures, and the architectural and training lessons that led to π0.
DP3 and iDP3: Improving Diffusion Policy Generalization with 3D Inputs
Yanjie Ze and Huazhe Xu discuss 3D representations, data efficiency, dexterous manipulation and generalization from a single training environment.
RFM, Episode 1: Physical Intelligence, π0 and the Robot Foundation Model Recipe
Complete notes from Sergey Levine’s CoRL 2024 talks on cross-embodiment data, π0, pre-training, post-training and reinforcement learning on real robots.
A Conversation with Jianlan Luo: Reinforcement Learning Can Work Directly on Real Robots
Jianlan Luo on SERL and HIL-SERL, sample-efficient real-world reinforcement learning, human interventions, precise manipulation and the limits of simulation.
Robot Data, Episode 10: A Full Review of Season 1
Revisiting all nine Season 1 interviews: human videos, simulation, motion capture, teleoperation and the composition of heterogeneous robot data.
Robot Data, Episode 9: Lirui Wang on Heterogeneous Robot Data and Policy Composition
The complete PoCo interview on combining simulation, human video, real robots and tactile information, followed by HPT, fleet learning and a personal reflection.
Robot Data, Episode 8: Chuang Gan and Zhou Xian on RoboGen, Generative Simulation and Differentiable Physics (With a Research Review)
A full interview on generating robot demonstrations, learning skills with differentiable simulation, and the research behind key physics platforms.
Robot Data, Episode 7: Hang Zhao and Ziwen Zhuang on Parkour and Autonomous Driving
The complete discussion of locomotion, simulation, reinforcement learning, RGB perception and lessons from autonomous-driving data loops.
Robot Data, Episode 6: Yecheng Jason Ma on Eureka, DrEureka and LLMs for Simulation and Reinforcement Learning
A full conversation on automatic reward design, domain randomization, sim-to-real transfer, reinforcement learning and VIP.
Robot Data EP05: Zipeng Fu on HumanPlus and Mobile ALOHA—From Synthetic Data to Real Data, and Combining the Two
Zipeng Fu discusses how HumanPlus and Mobile ALOHA use simulation, human motion and real-world teleoperation data to train robots.
Robot Data, Episode 4: Chen Wang on MimicPlay, DexCap and Learning from Human Motion
The full interview on hierarchical planning, human play, wearable motion capture, retargeting, dexterous control and the differences between DexCap and UMI.
Robot Data: Xuxin Cheng on Immersive Robot Teleoperation with Open-TeleVision
Xuxin Cheng discusses stereo vision, active head movement, motion retargeting and learning robot skills from immersive teleoperation.
Robot Data, Episode 2: Cheng Chi and Zhenjia Xu on UMI, a Physical API for Robot Training
A 2024 conversation with Cheng Chi and Zhenjia Xu about UMI’s handheld hardware, data collection, policy learning and generalization.
Robot Data EP01: Yang Gao and Chuan Wen on Learning Robot Policies from Internet Videos with ATM
The ATM authors discuss point trajectories, cross-embodiment learning and using human videos to reduce the need for action-labeled robot data.
Inside RFM-1: An Interview with Covariant Co-founder Peter Chen
A March 2024 interview with Peter Chen on RFM-1, robot foundation models, real-world data, world models and commercial deployment.
Fifteen Years of GelSight: A Brief History of Vision-Based Tactile Sensors
From surface metrology in 2009 to robot fingertips, soft hands and commercial sensors: GelSight’s research history and the opportunities and challenges of camera-based touch.
Talking Simulation, Part 2: An Interview with the Simulately Contributors
Yuzhe Qin and Haoran Geng discuss the robotics simulation ecosystem, sim-to-real transfer, reinforcement and imitation learning, and the challenges of building useful simulators.
Let's Talk About Sim, Part I: The Robot Simulator Ecosystem
A full guide to general-purpose robot simulators, physics engines, household simulation environments and specialized tools.
Embodied AI Super Dialogue: How Artificial Intelligence Is Leading the Robotics Revolution
A full conversation with Peter Chen, Huazhe Xu, Xiaolong Wang and Qiuguo Zhu about learning, control, reliability, safety and practical deployment.
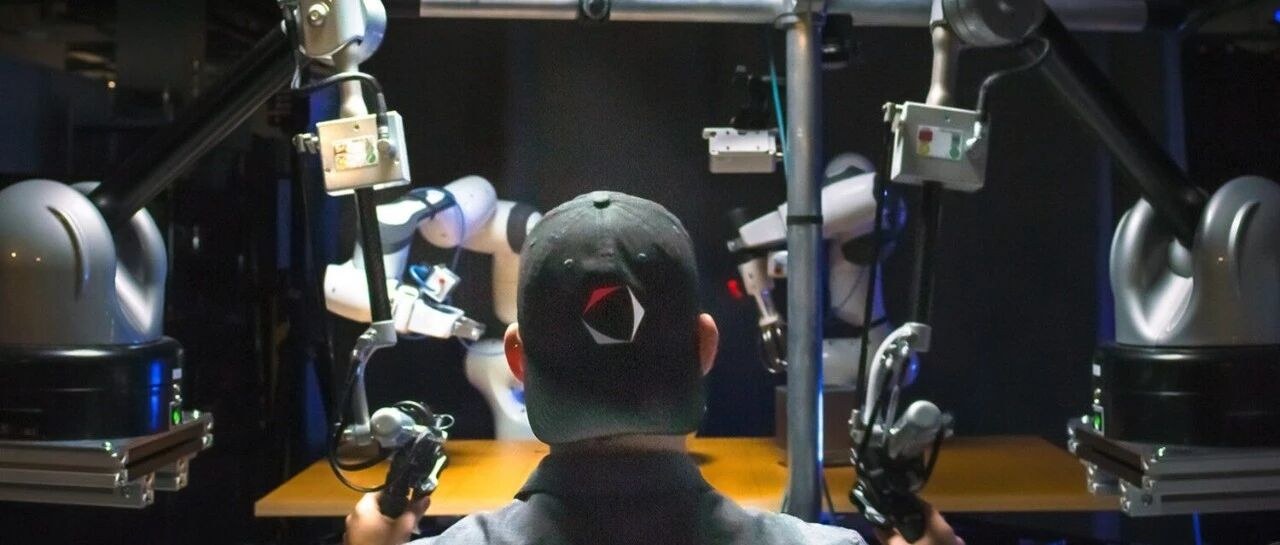
Diffusion Policy: Generating Robot Actions with Diffusion Models
An interview with Cheng Chi explaining Diffusion Policy, multimodal action distributions, coherent action sequences and the data needed for general-purpose robots.
Can Foundation Models Bring Us General-Purpose Robots?
A full account of the CoRL 2023 scaling debate: data, embodiment, reliability, long-horizon control, human intervention and an investor’s reflections.
Bringing Robot Hands Closer to Human Hands: A Review of Dexterous Manipulation Research by Chinese Researchers
A 2023 review of robotic hands, rigid and deformable manipulation, imitation learning, teleoperation and multimodal sensing, with research demonstrations.
A Map of Chinese-Origin Researchers in AI + Robotics
Research lineages, universities, laboratories and Chinese-origin researchers at the intersection of AI and robotics, as surveyed in September 2023.
Mapping the Major Centers of Legged Robotics
A 2023 overview of influential legged robotics laboratories, their spinouts and leading humanoid and quadruped companies.
No matching articles.
ReSpark
PodcastA conversation worth staying for.
Conversations with researchers and founders about AI, robotics, and the questions that move their work forward.
Listen on Apple PodcastsEpisodes are primarily in Mandarin.